Robotics MS · UC San Diego
Nathan Van Utrecht
I work on state estimation, robot learning, and control. Right now I'm in Xiaolong Wang's lab, teaching simulators to behave more like the real robots they stand in for.
Before this: internships at Brain Corp, John Deere, and Grace Technologies, and two research positions at Iowa State.
Live: frontier exploration, A* planning, 2D lidar. Click to set a goal.
Toolkit
What I reach for
- Estimation & SLAM
- EKF, factor graphs (GTSAM), bundle adjustment, ICP, camera calibration
- AI evaluation
- Golden datasets, commit-pinned eval runs, regression diffs, agent harnesses
- Robot learning
- PPO, SAC, BC / GAIL / AIRL, sim-to-real, PyTorch, Gymnasium
- Perception
- Multi-camera geometry, stereo depth, lidar fusion, YOLOv8, CNNs, ViTs
- Planning & control
- Kinematics, trajectory planning, Koopman models, ROS
Work
11 projects, 2023 to 2026
-
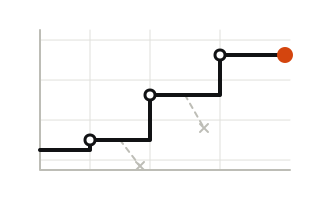 AI hill-climbing on a robot perception pipeline Coding agents propose a change, run the real pipeline pinned to that commit, and score it against a 25k-label golden set. Held-out precision rose 0.49 → 0.95 at full recall, and the winning change shipped to production. LLM agents, golden datasets, regression diffs Learning 2026
-
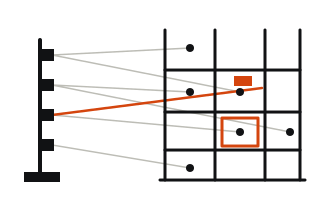 Pixels to meters: pallet mapping Projects each barcode read from a 4-camera tower onto the rack face in world coordinates, replacing pixel heuristics. False exceptions fell 90% at 100% recall, now live at 10+ customer sites. Multi-camera geometry, calibration, pose graphs Perception 2026
-
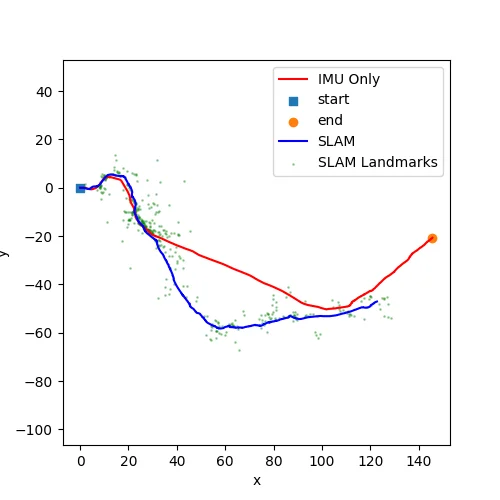 Visual-inertial SLAM A joint EKF on SE(3) that fuses IMU kinematics with optical-flow stereo features, bounding the drift of IMU-only dead reckoning on a Clearpath Jackal. EKF, sensor fusion, stereo vision Estimation 2026
-
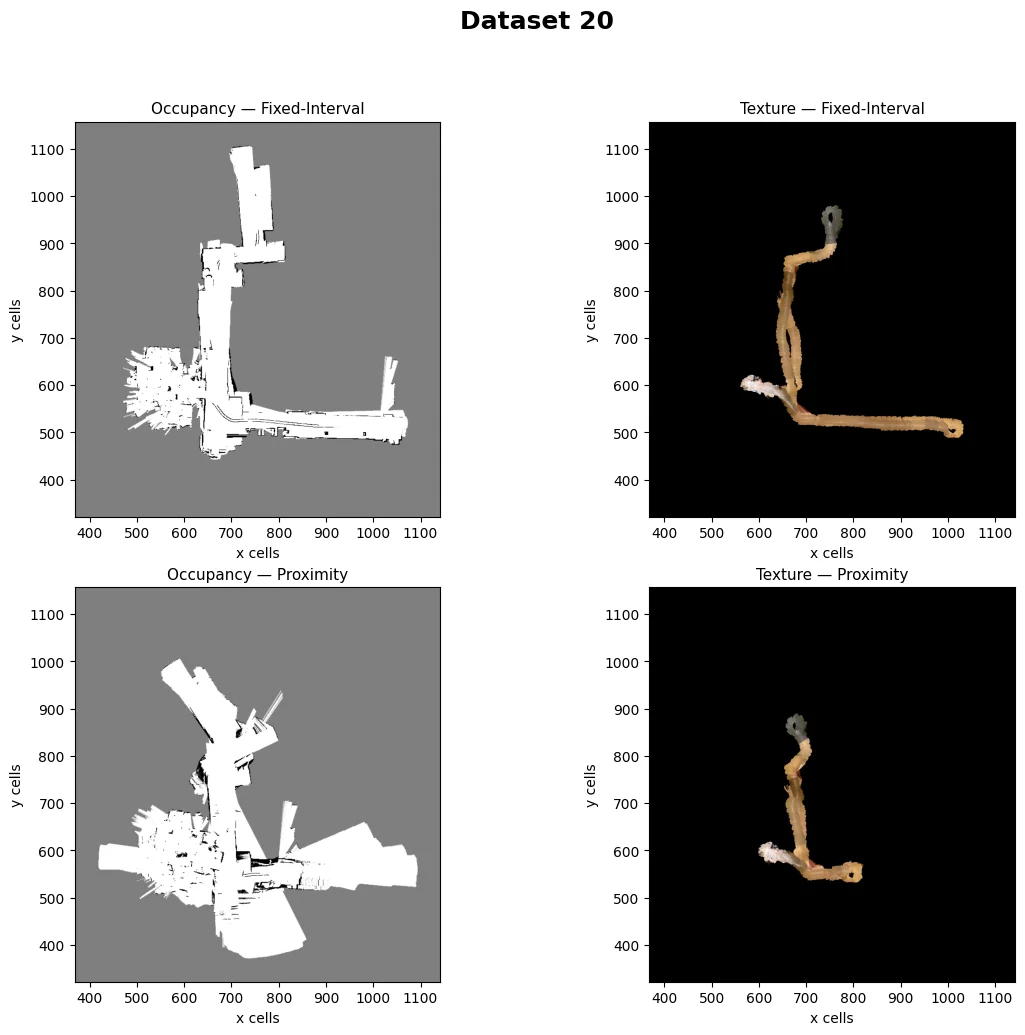 LiDAR SLAM with factor graphs Odometry, ICP scan matching, and GTSAM pose-graph optimization. Proximity-based loop closures cut total graph error 65%, against 43% for fixed-interval ones. GTSAM, ICP, pose graphs Estimation 2026
-
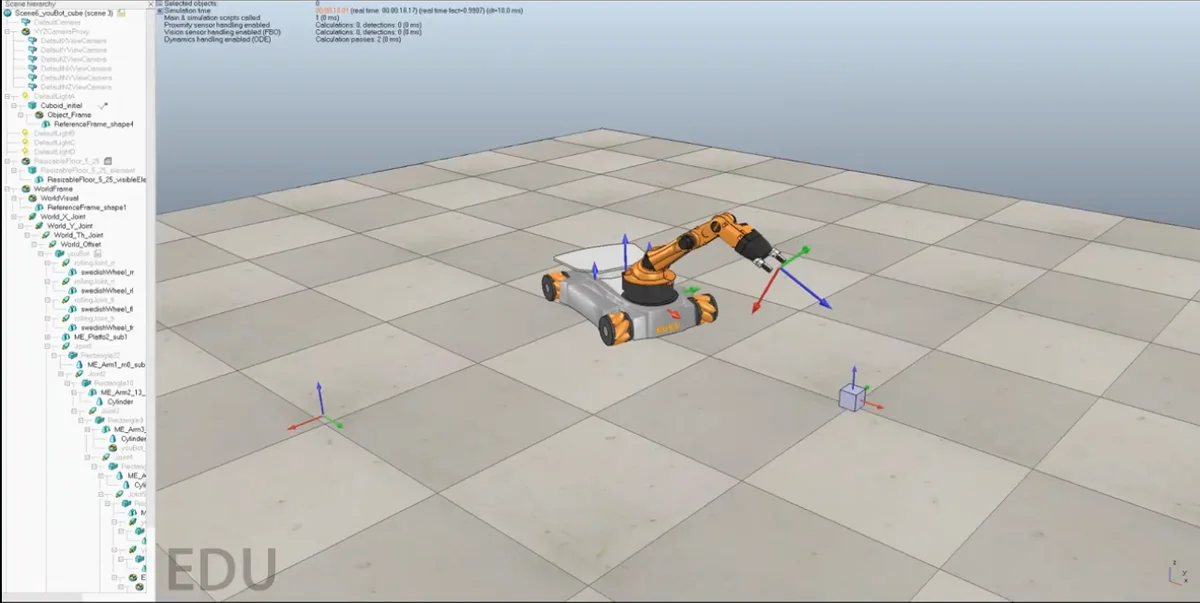 Mobile manipulator pick-and-place Kinematics, 8-segment screw trajectories, and a feedforward + PI controller for a KUKA youBot. End-effector error converges within 5 s with little to no overshoot. Kinematics, trajectory planning, CoppeliaSim Control 2026
-
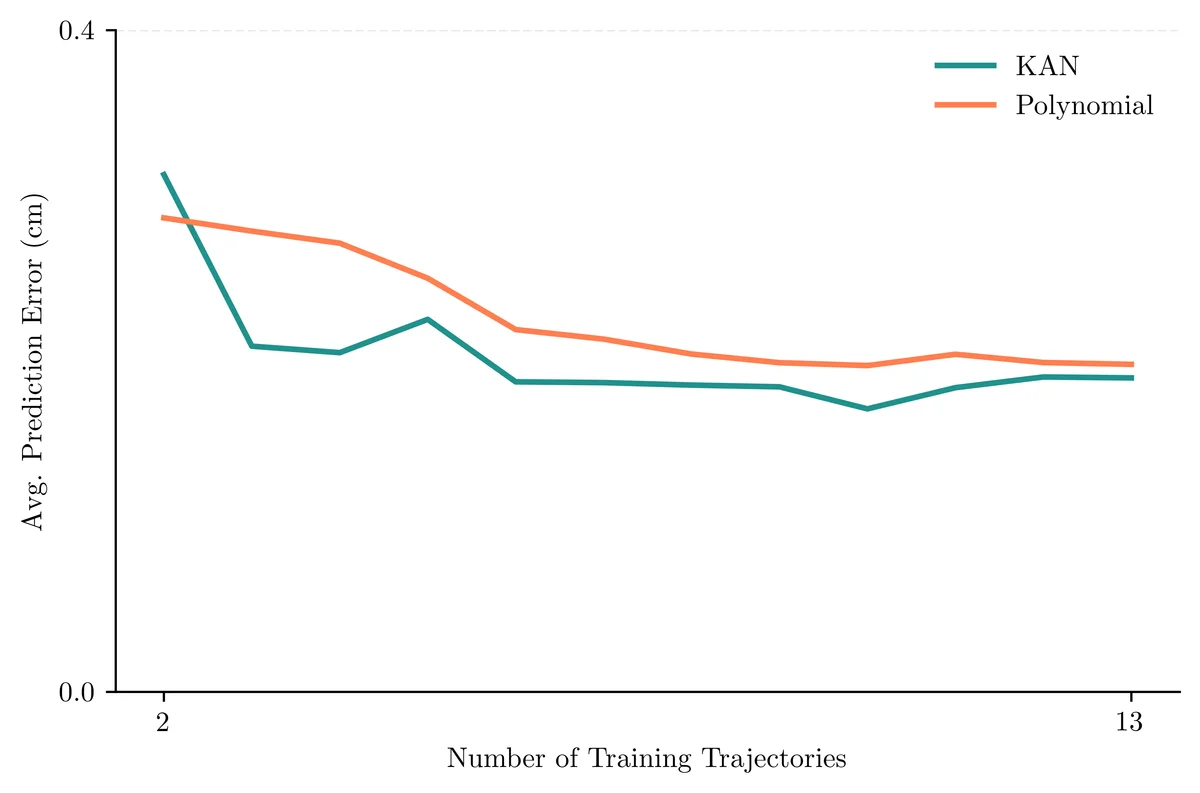 Koopman models with KANs Kolmogorov-Arnold Networks as learned Koopman observables for a soft robot arm. Needs under half the training data of a polynomial EDMD baseline and runs in ~2 ms. PyTorch, Koopman operators, soft robotics Learning 2025
-
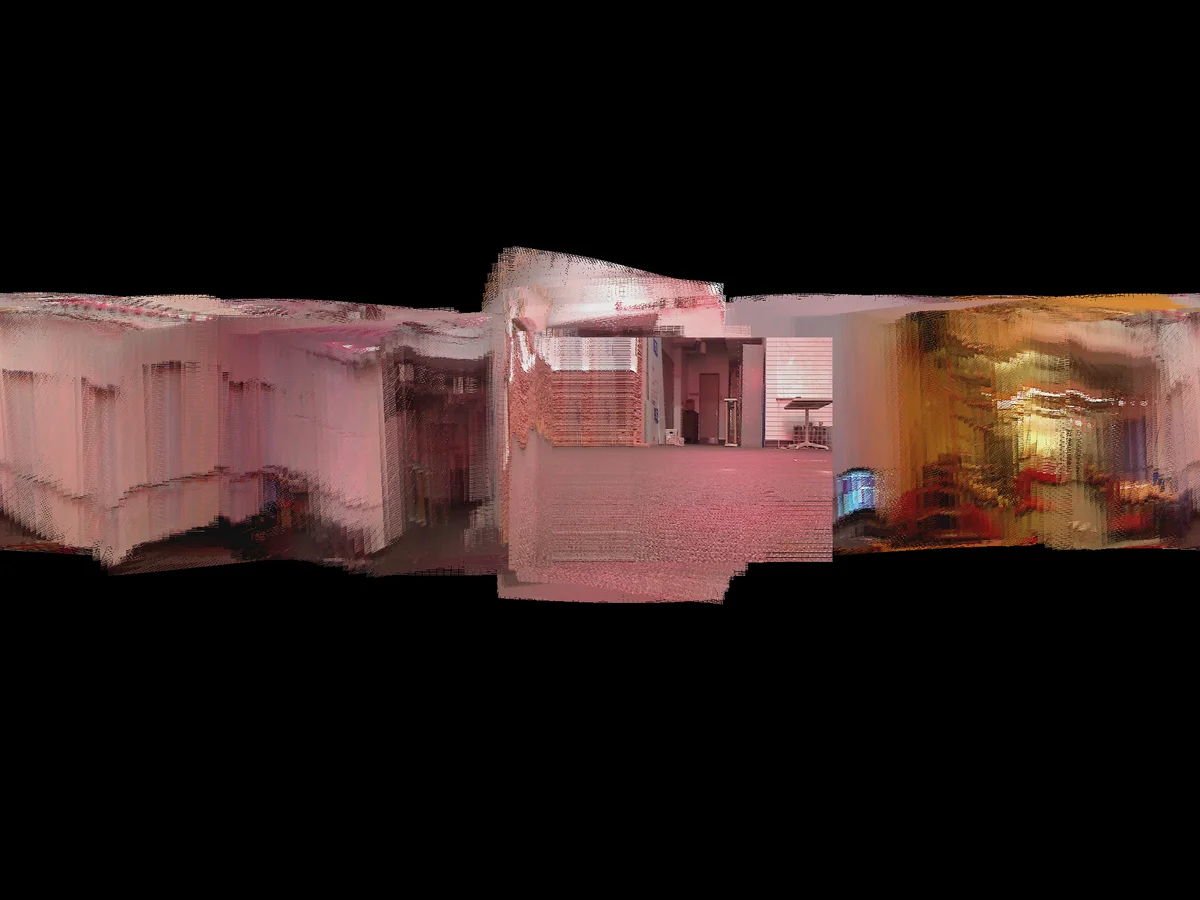 IMU orientation tracking & panoramas Projected gradient descent over unit quaternions tracks IMU orientation against VICON ground truth, then stitches camera frames into a 2048×1536 panorama. Quaternions, constrained optimization Estimation 2026
-
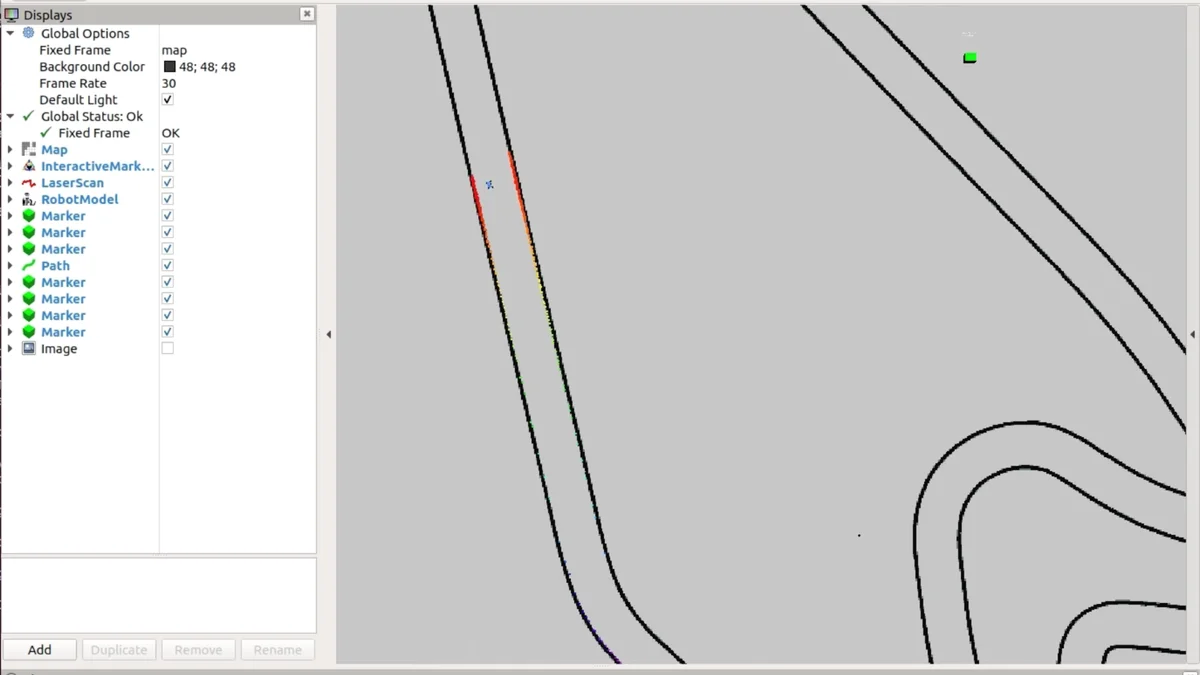 F1Tenth autonomous racing A follow-the-gap planner on raw LiDAR that laps the Nürburgring in the F1Tenth simulator, with separate fast and smooth modes. ROS, LiDAR, reactive planning Control 2023
-
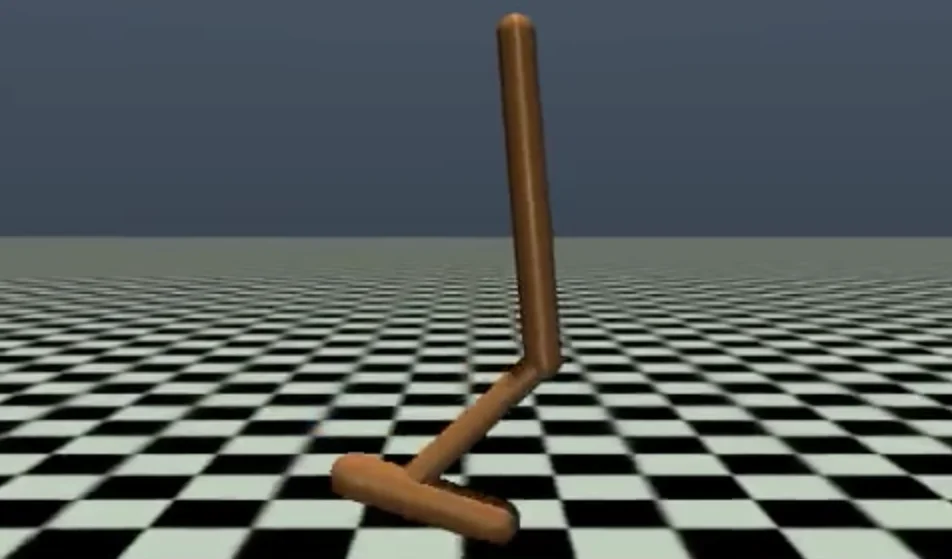 PPO from scratch Proximal Policy Optimization written in PyTorch and trained on four Gymnasium tasks, from CartPole and LunarLander to MuJoCo Hopper and HalfCheetah. PyTorch, Gymnasium Learning 2024
-
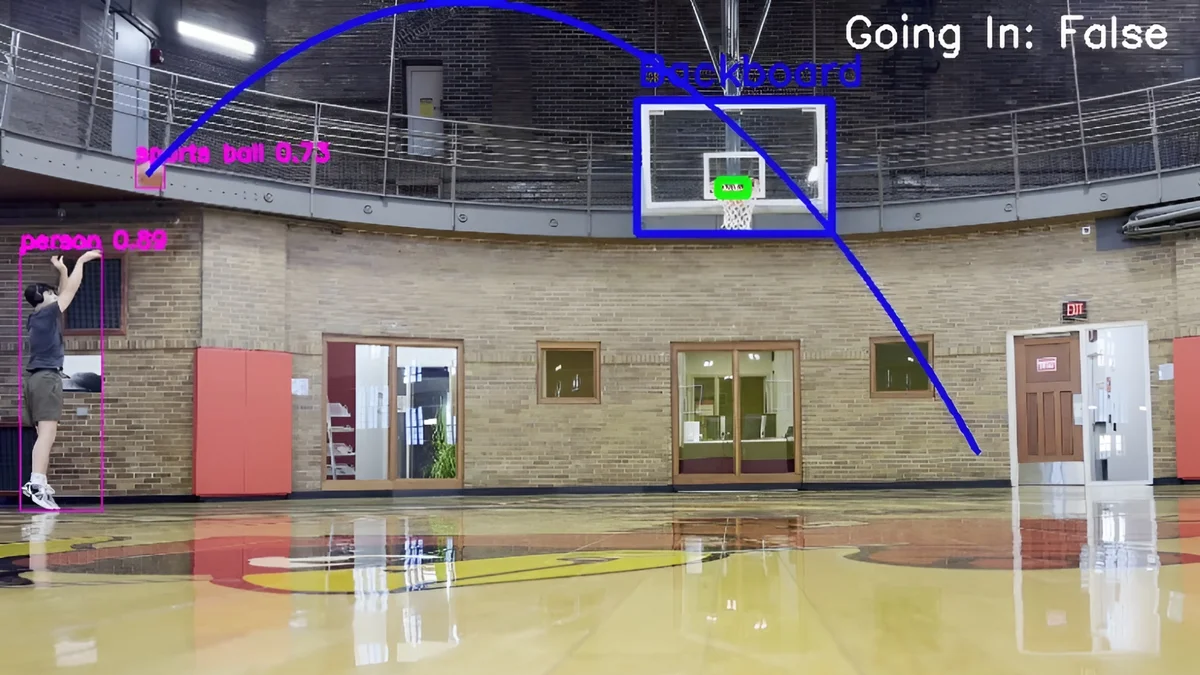 Basketball shot detection YOLOv8 and segmentation track the ball, and a fitted trajectory calls make or miss. YOLOv8, transfer learning Perception 2024
-
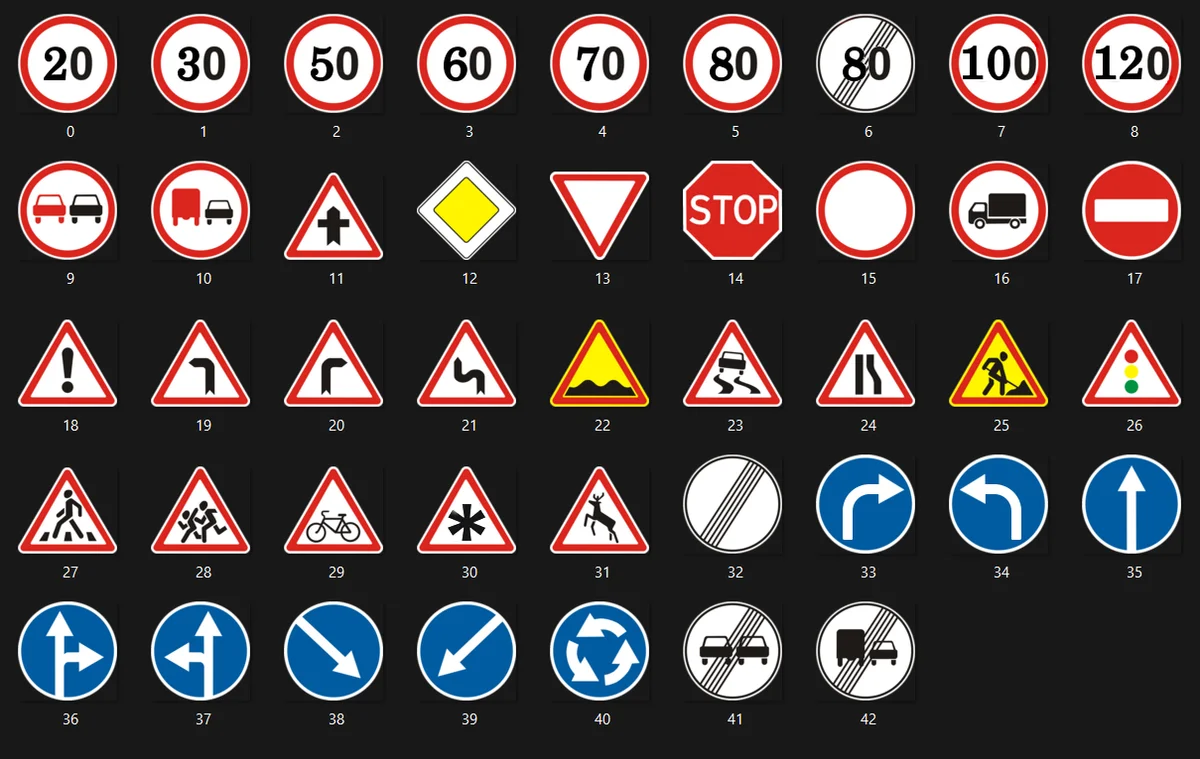 Traffic signs under occlusion Five models compared on occluded signs. A small custom CNN hit 95.9% accuracy at 1 ms per image; ResNet-50 reached 98.2% but ran 4.6× slower. CNNs, ViTs, data augmentation Perception 2024
Experience
3 research, 3 industry
| Date | Where | Notes |
|---|---|---|
| 2026 – now | Xiaolong Wang Lab Graduate researcher, UC San Diego Research | Using real-world robot data to make simulation more faithful, so learned policies survive the move to hardware. |
| 2026 | Brain Corp Software engineering intern, San Diego Industry | Built an eval harness that lets AI coding agents hill-climb a warehouse robot's perception pipeline against a 25k-label golden set; held-out precision rose 0.49 → 0.95 at full recall. With my move to metric world-coordinate association, false exceptions fell 90% in production. Also debugged deployed robots down to the core dump. |
| 2024 – 25 | Coordinated Systems Lab Honors researcher, Iowa State Research | Stress-tested BC, GAIL, and AIRL under shifted physics and goals. Wrote it up as my honors thesis. |
| 2024 | TrAC REU Research intern, Iowa State Research | Benchmarked model-based and model-free RL for sim-to-real. SAC reached an expert policy 5× faster. |
| 2023 | John Deere Engineering intern, Product engineering Industry | Took a tool-storage bracket from Creo concept to physical test; FEA cut its weight 15%. Four CAD concepts for new tractor cab features. |
| 2022 – 23 | Grace Technologies Engineering intern, IIoT engineering Industry | Six Python validation suites (>80% less manual testing) and a field debugger that cut callbacks 40%. |